In your operation
Study body and hand coordination
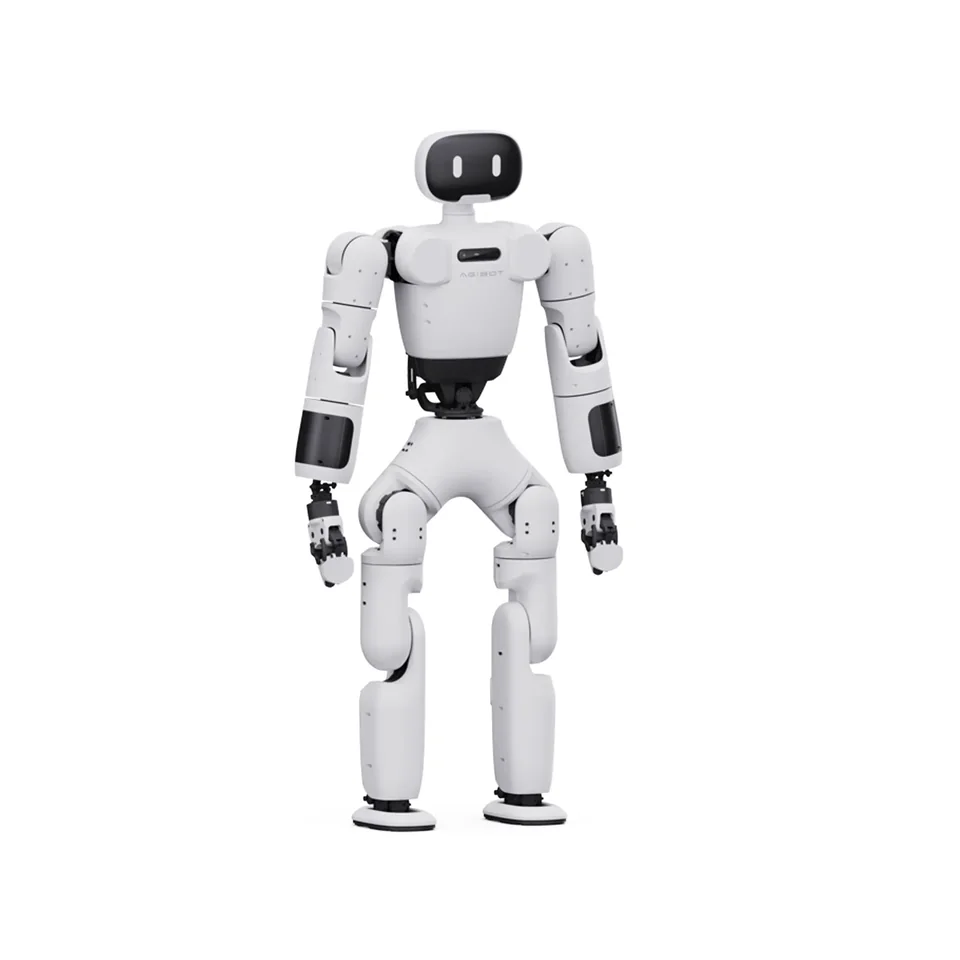
GR-1 gives robotics teams a full-size platform for developing motion and manipulation together.
Buy Short-term rent Long-term rent RaaS
Deployment and support across MENA
FourierHumanoids
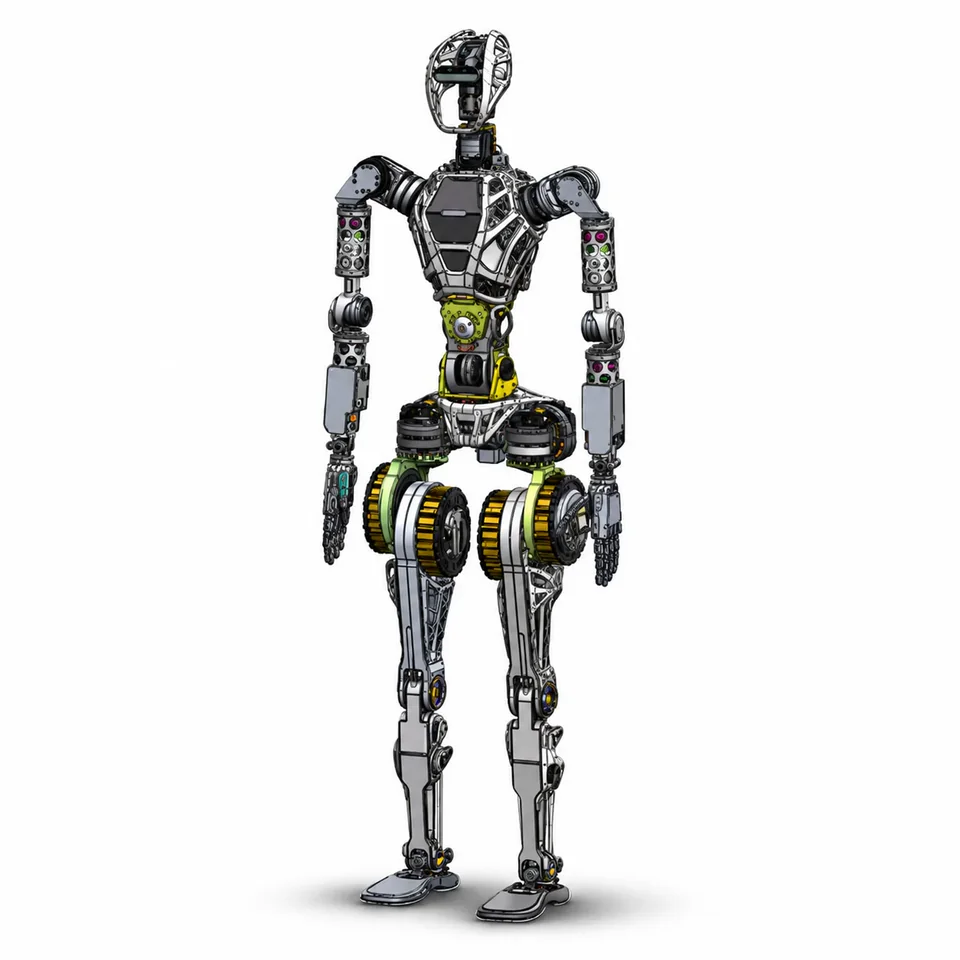
GR-1 combines a 1.65 m body with 44 actuators and dexterous hands. It provides a platform for whole-body motion and manipulation research, with a published 3 kg load per hand.
Indicative budget only, not a confirmed Saudi retail offer. Configuration, freight, tax, deployment and service are confirmed in your quotation. Rental and RaaS figures are planning estimates.
GR-1 gives robotics teams a full-size platform for developing motion and manipulation together.
The brochure specifies 3 kg per hand. Choose test objects and grasps within that rating.
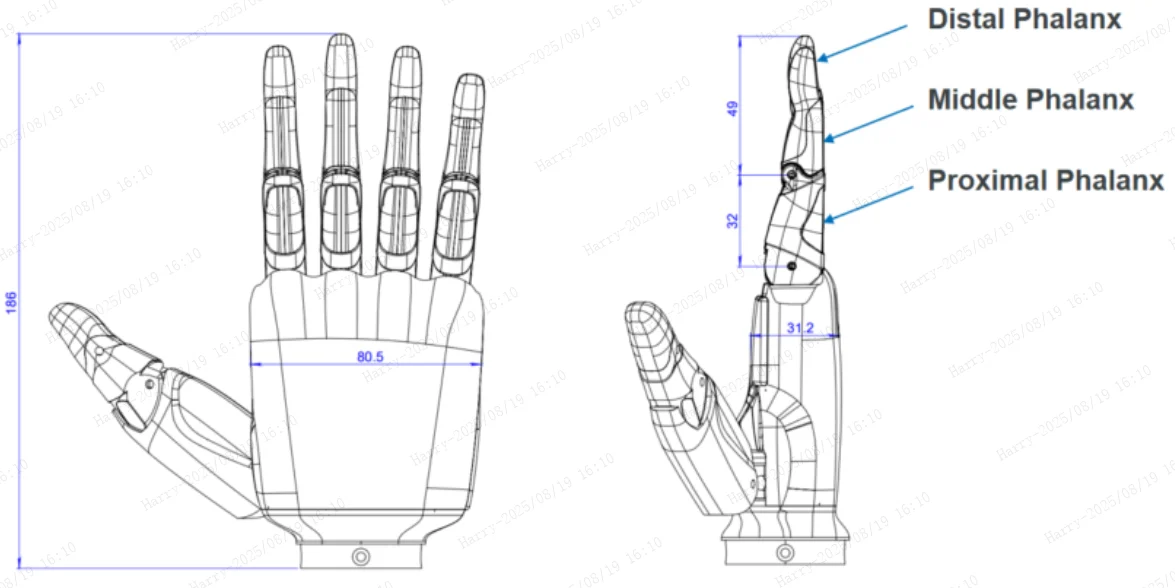
Fourier maps GR-1 with dexterous hands to GR1T1. GR-1L uses a jaw gripper; the Pro models map to GR1T2. Keep the robot model, hand and controller configuration aligned.
Fourier publishes GR1T1 robot models and ROS/Gazebo examples. Its teleoperation project recommends the legacy GRx backend for GR1T1 and GR1T2, with separate hand and camera configurations.
The published walking speed is 5 km/h. Set test speeds and movement boundaries around the experiment and available lab space.
GR1T1 with dexterous hands for supervised whole-body motion and manipulation research. Software integration and lab setup form the research project.
Manufacturer-documented connections and compatible equipment. Building interfaces are checked against your installation.
GR1T1 and GR1T2 models with ROS/Gazebo examples.
Legacy GRx backend for GR1T1/GR1T2; hand and camera configuration is part of development.
The GR1T1 configuration with dexterous hands. Fourier distinguishes it from GR-1L with a jaw gripper and the GR1T2-based Pro models.
Fourier's public models, ROS/Gazebo examples and teleoperation project provide a starting point for simulation and control. These are development tools, not a finished task application or a promise that extra hand, camera or headset hardware is included.
Compare the approaches and site requirements in these related solution guides.
We help define the right setup for your operation, from site assessment and integration to team training and ongoing support.
Equipment, installation and service responsibilities are agreed in your proposal.
Discuss your deploymentShare your task and location. We’ll help define the configuration and commercial terms.