In your operation
Capture demonstrations as training data
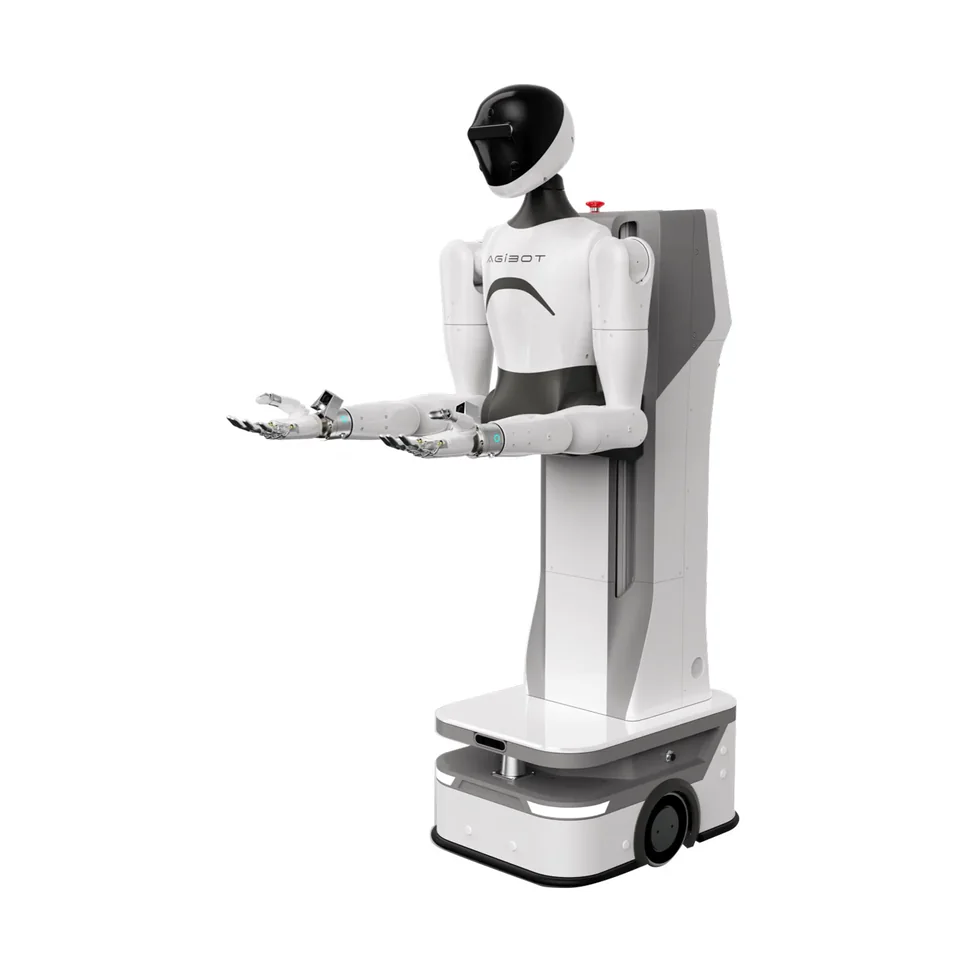
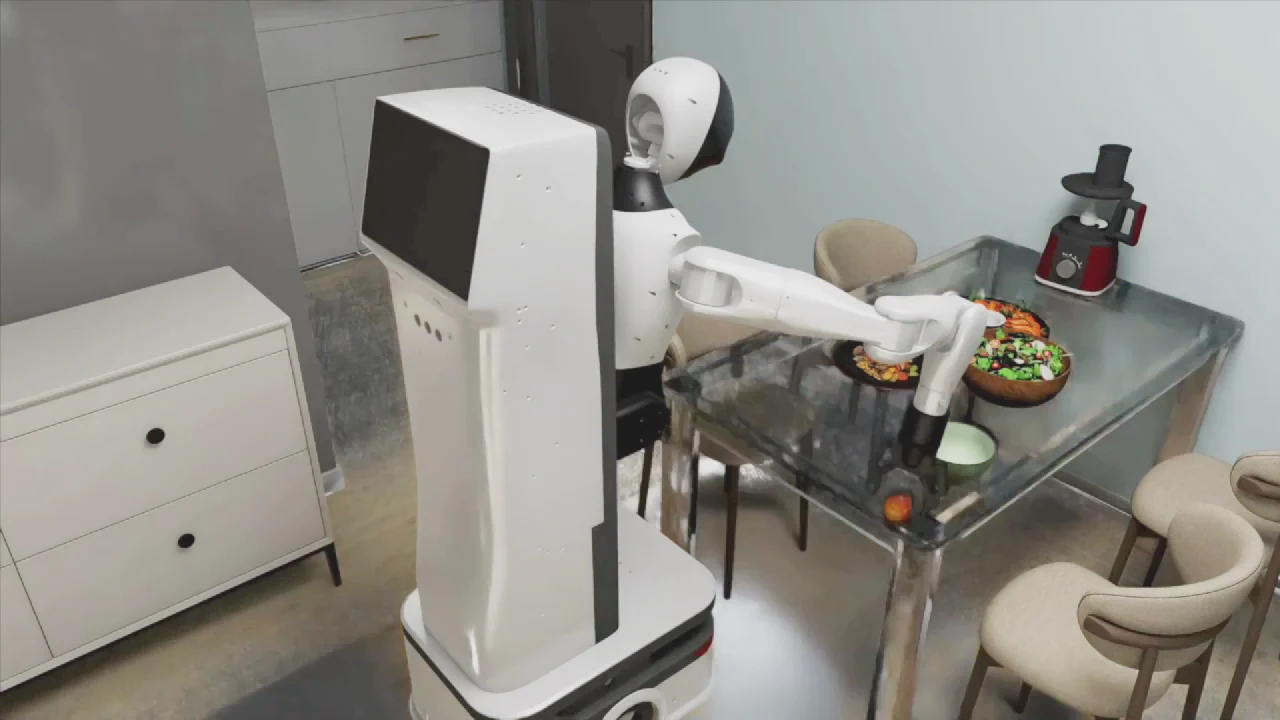
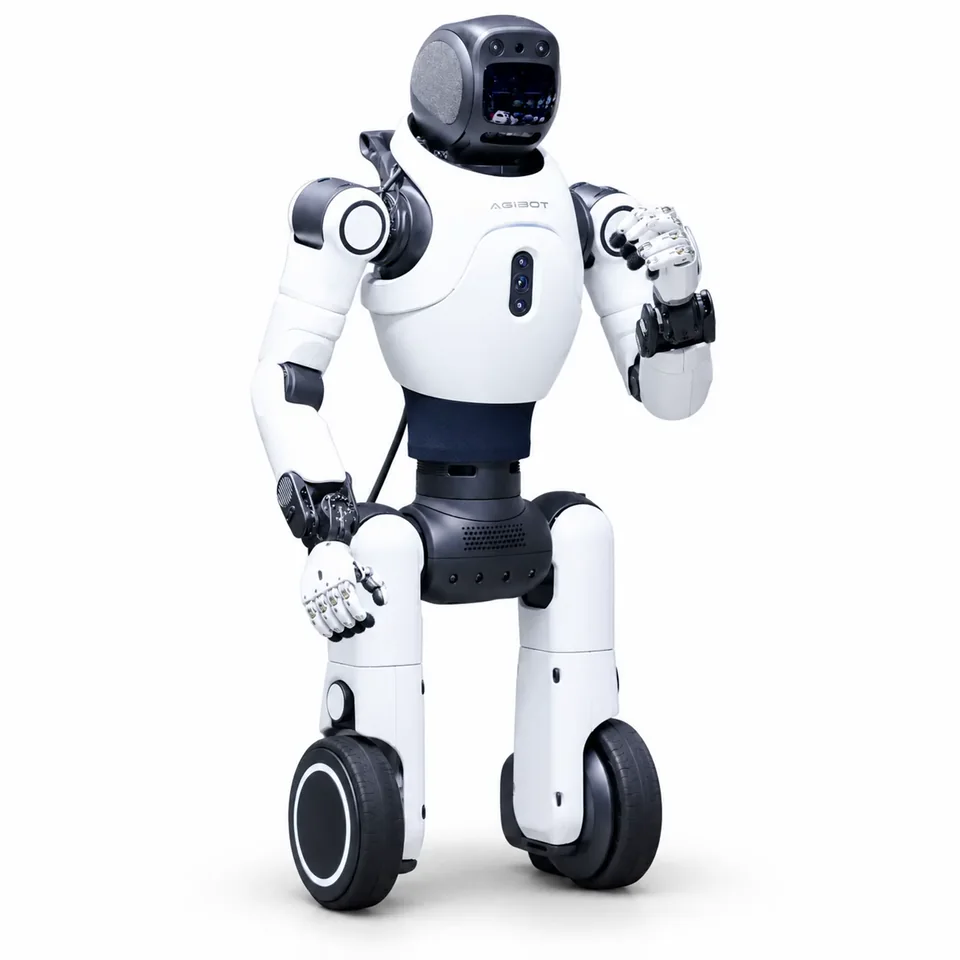
G1 supports remote operation with full-body joint recording, helping teams collect manipulation demonstrations.
Buy Short-term rent Long-term rent RaaS
Deployment and support across MENA
AGIBOTHumanoids
G1 records full-body joint data during teleoperation and supports model inference on a Jetson AGX Orin computer. A variable-height body, force sensors and cameras support manipulation experiments at different work surfaces.
Indicative budget only, not a confirmed Saudi retail offer. Configuration, freight, tax, deployment and service are confirmed in your quotation. Rental and RaaS figures are planning estimates.
G1 supports remote operation with full-body joint recording, helping teams collect manipulation demonstrations.
AGIBOT describes continuous operation while one arm holds a 3 kg object. Treat this as the published object-holding case, not a load rating for every reach, motion or replacement gripper.
Six-axis force sensors on both arms and multiple cameras provide force and visual inputs for manipulation work.
The collection workflow combines local and cloud data, automatic validation and manual review. Jetson AGX Orin provides the onboard compute.
The HMI displays status and alarms, supports fault recovery and provides OTA updates. Published runtime is more than four hours.
Manipulation-data collection with a selected end effector and supervised object-handling sequence. The published 3 kg object-holding case is not a universal replacement-gripper rating.
Manufacturer-documented connections and compatible equipment. Building interfaces are checked against your installation.
Capture full-body joint data with local/cloud transfer and validation.
Robot status, alarms, recovery controls and software updates.
Continuous operation with one arm holding a 3 kg object. The claim concerns the held object; it does not establish a complete reach-versus-load chart for every end effector.
Yes. AGIBOT lists a replaceable end effector and a two-finger gripper option. The grip and motion are developed around the selected object.
G1 is a platform for demonstration capture and model inference. The production task, trained behaviour and equipment integration form the application.
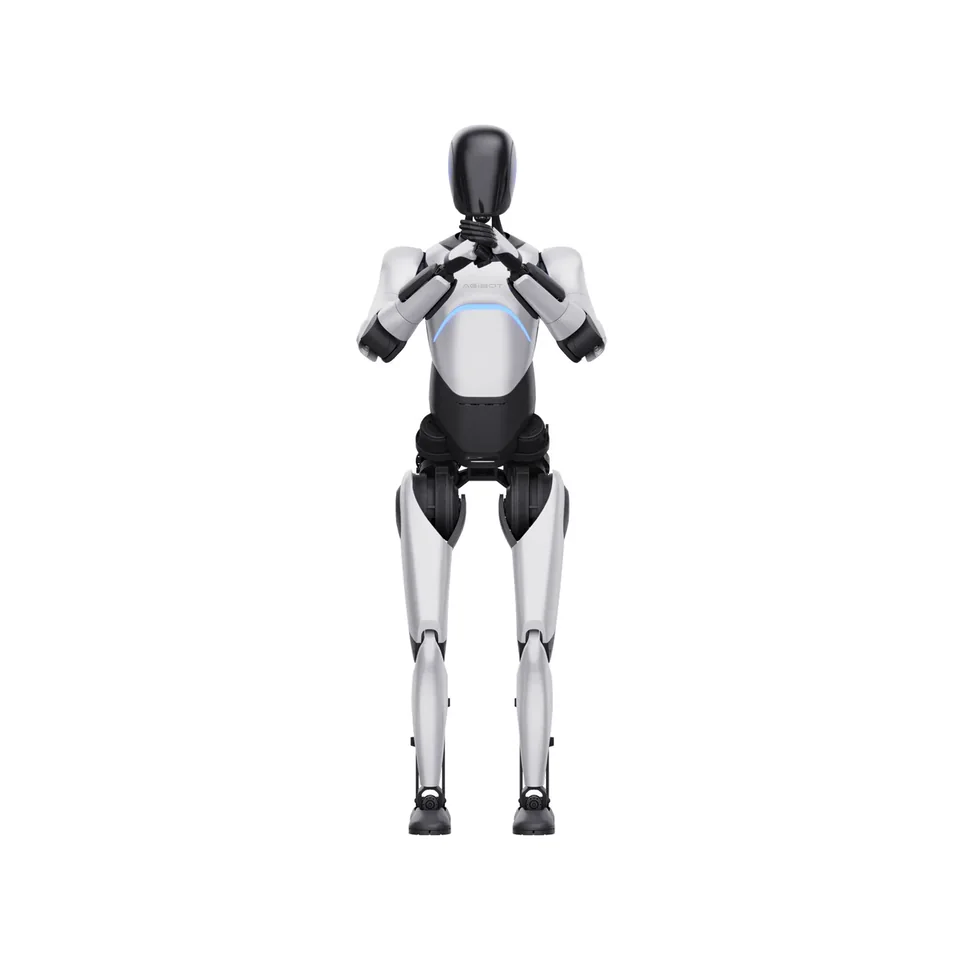
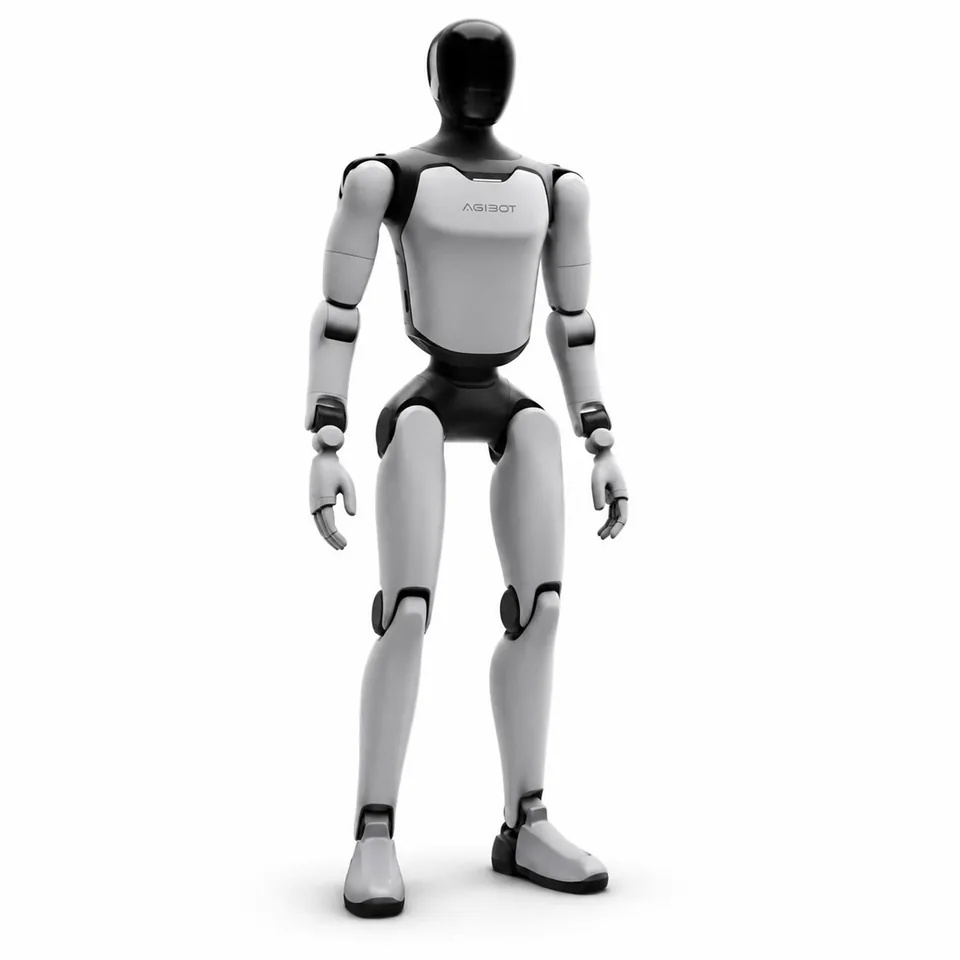
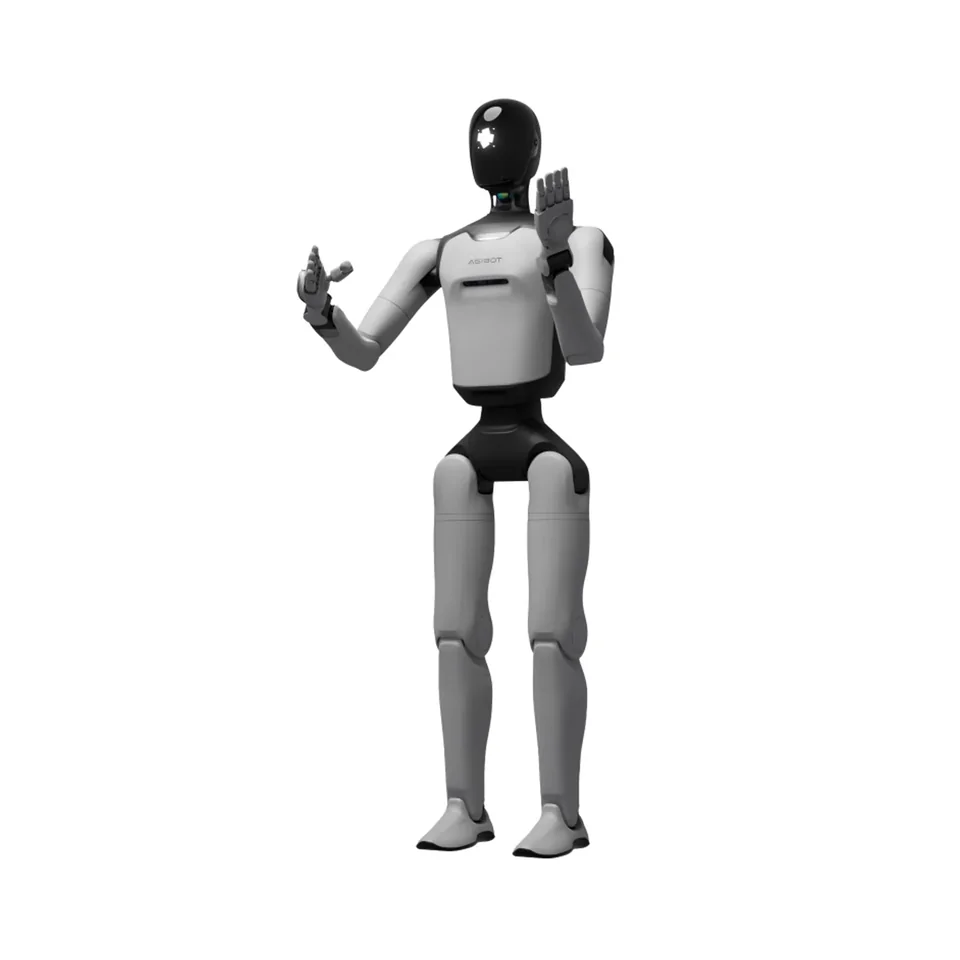
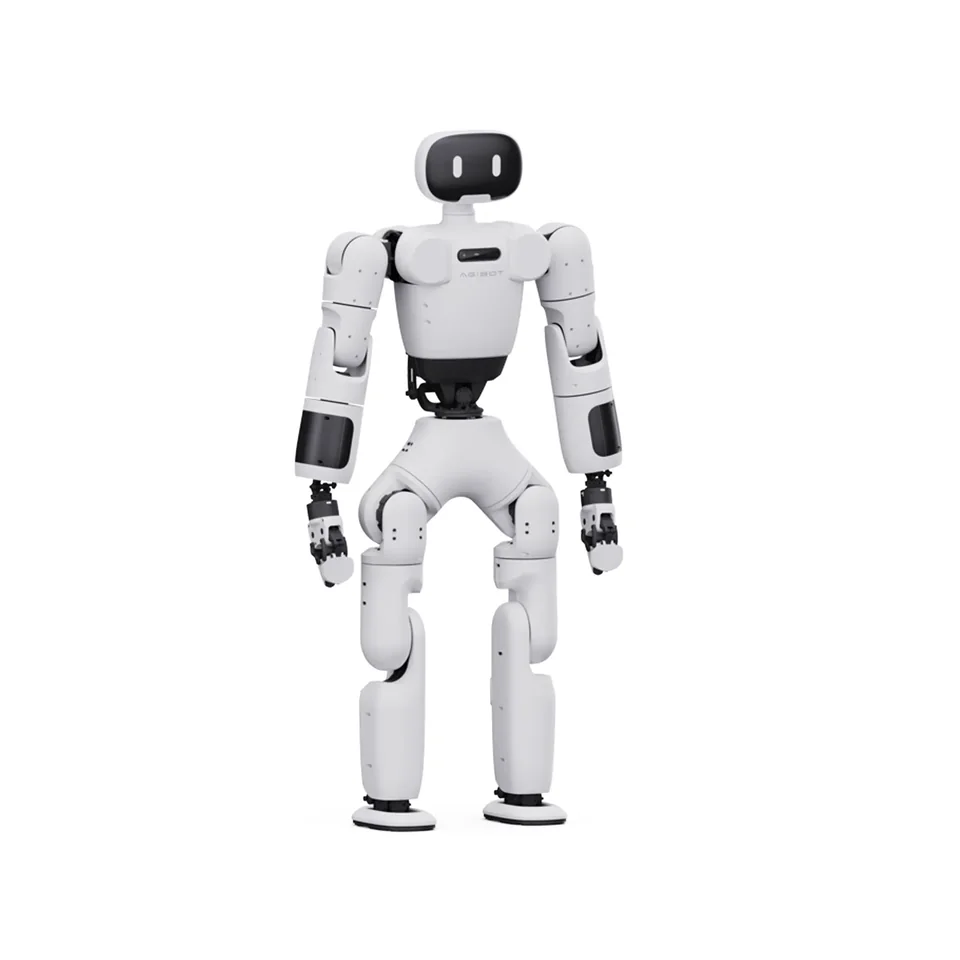
Compare the approaches and site requirements in these related solution guides.
We help define the right setup for your operation, from site assessment and integration to team training and ongoing support.
Equipment, installation and service responsibilities are agreed in your proposal.
Discuss your deploymentShare your task and location. We’ll help define the configuration and commercial terms.